Use cases

Mobile robotics projects and use cases

Representative architectures for the problems we address: ROS 2 software, autonomous navigation, sensor fusion, perception and mobile platform integration.

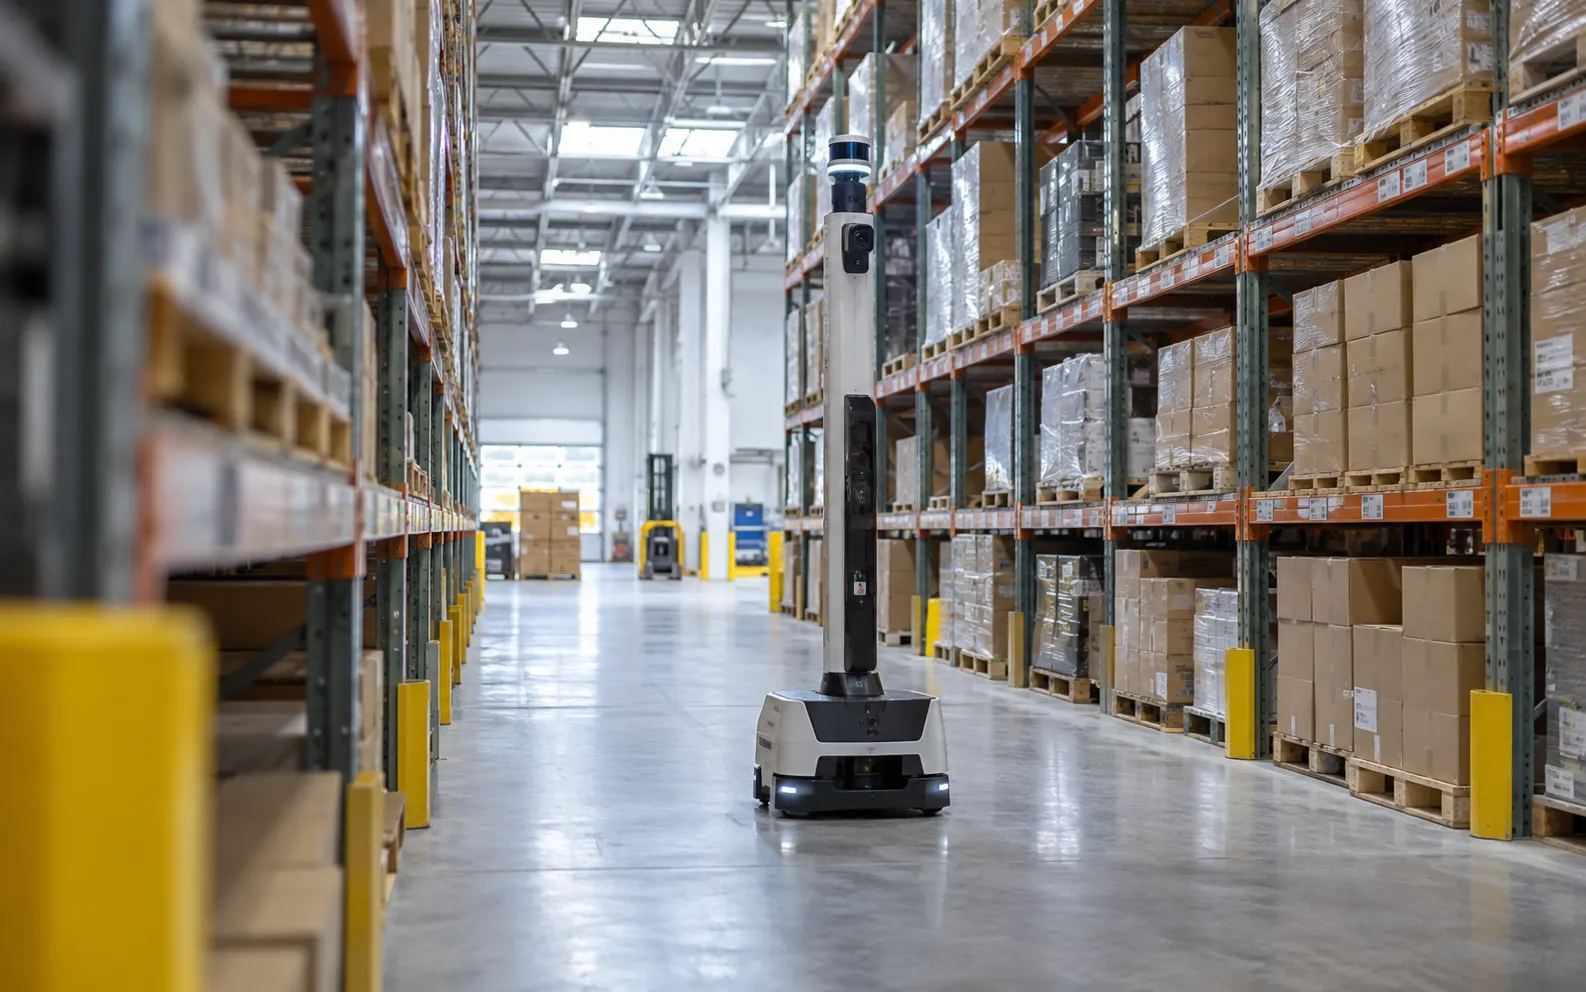
Autonomous mobile robot carrying out inventory checks

Example projects

Prototypes reflecting the needs we support.

The projects below illustrate possible types of engagement. Client details, measured results and actual photographs can be added once the information has been validated.

Robotics architecture

ROS 2 autonomous mobile base

Problem
Structure a mobile platform’s software and make its components integrable and observable.
Solution
ROS 2 architecture with drivers, TF, ros2_control, Nav2 navigation and diagnostic tools.
Constraints
Latency, embedded resources, consistent coordinate frames and error recovery.
Outcome
A modular software foundation ready for testing and additional behaviors.
  • ROS 2
  • Nav2
  • C++
  • ros2_control
  • Linux

Autonomous navigation

Multi-sensor localization

Problem
Maintain a usable pose estimate despite wheel slip and visually sparse areas.
Solution
Fuse odometry, IMU and LiDAR with calibration and uncertainty analysis.
Constraints
Vibration, drift, time synchronization and robot geometry.
Outcome
Measurable localization with documented limits for field scenarios.
  • LiDAR
  • IMU
  • SLAM
  • robot_localization
  • rosbag

Robotics vision

Onboard camera perception

Problem
Detect obstacles and objects of interest within a limited computing budget.
Solution
Calibrated camera pipeline, OpenCV processing and ROS 2 result integration.
Constraints
Lighting, occlusion, latency and computer power consumption.
Outcome
A reproducible pipeline evaluated on representative sequences.
  • RGB-D camera
  • OpenCV
  • ROS 2
  • C++
  • Edge computing

Mobile platform

Mechanical and electronic prototype

Problem
Combine locomotion, power, computing and sensors within a constrained volume.
Solution
Chassis design, drivetrain selection, power distribution and sensor mounts.
Constraints
Payload, runtime, heat dissipation, vibration and maintenance access.
Outcome
An integrated mobile platform for validating technical choices.
  • CAD
  • CAN
  • BLDC motors
  • LiDAR
  • embedded computing
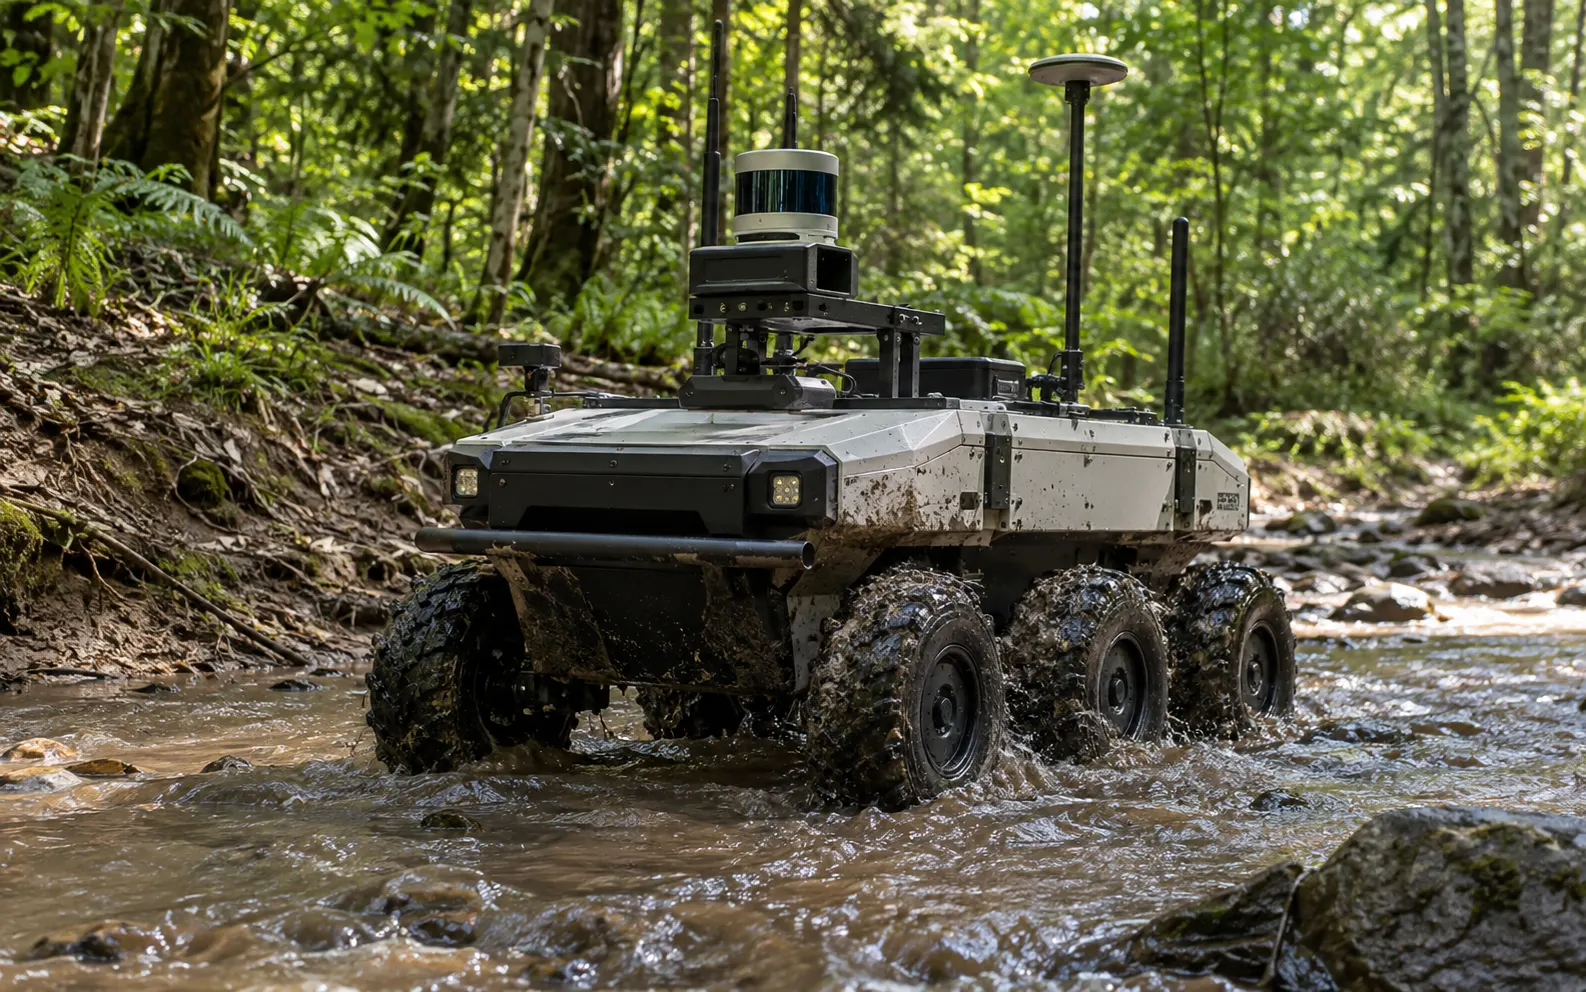
All-terrain mobile robot crossing a river

Project

Are you developing a mobile robot?

Let’s discuss the expected behavior and challenges to address.