Software
Robotics software development
ROS 2 architecture, drivers, control and simulation for mobile robots.
Explore our expertise Yokaï Robotics
Mobile robotics engineering
Discuss your project
Mobile robotics engineering
Robotics software, navigation, camera and LiDAR perception, electronics and mechanics: we develop your mobile robot from end to end.
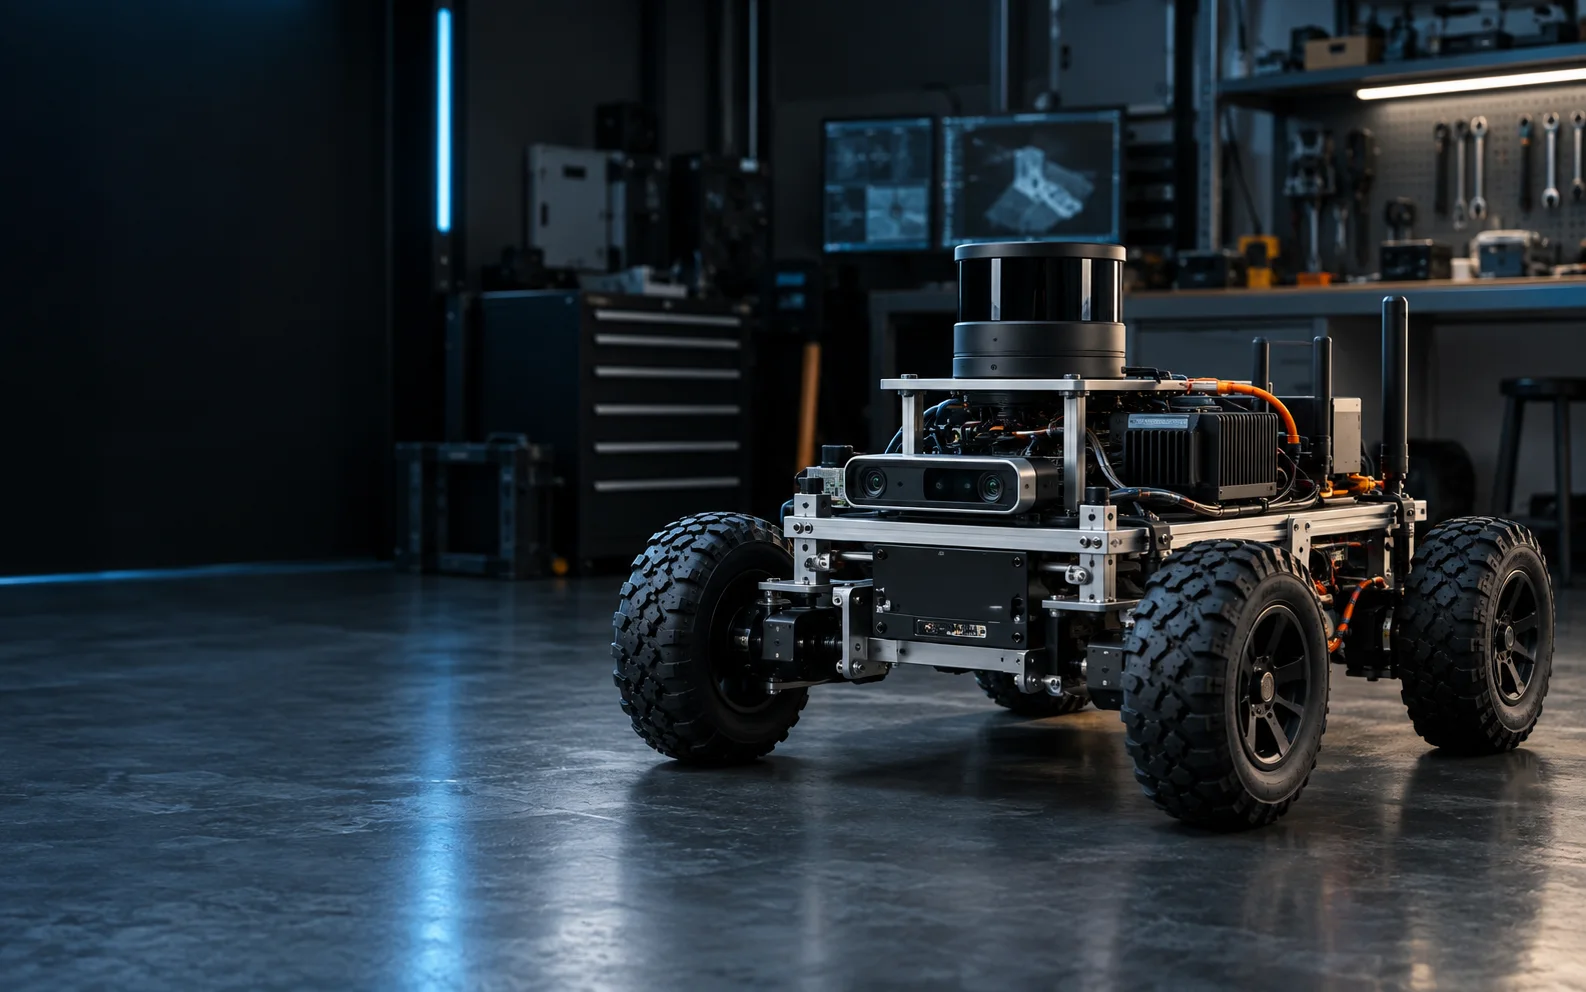
End-to-end expertise
Our engineering consultancy works across France to connect software, sensors, actuators and chassis within a coherent architecture.
Capabilities
Software
ROS 2 architecture, drivers, control and simulation for mobile robots.
Explore our expertiseAutonomy
Navigation, SLAM, sensor fusion, cameras and LiDAR.
Explore our expertiseElectronics
Embedded computing, sensors, power and motor control.
Explore our expertiseMechanics
Chassis, drivetrain and mechanical integration.
Explore our expertiseAutonomous navigation
Algorithms tailored to the robot, its sensors and its environment.
RGB-D and stereo cameras, 2D/3D LiDAR, IMU and odometry.
Sensor fusion, SLAM, mapping and pose estimation.
Global and local paths, obstacle avoidance.
Feedback control, motor control and field validation.
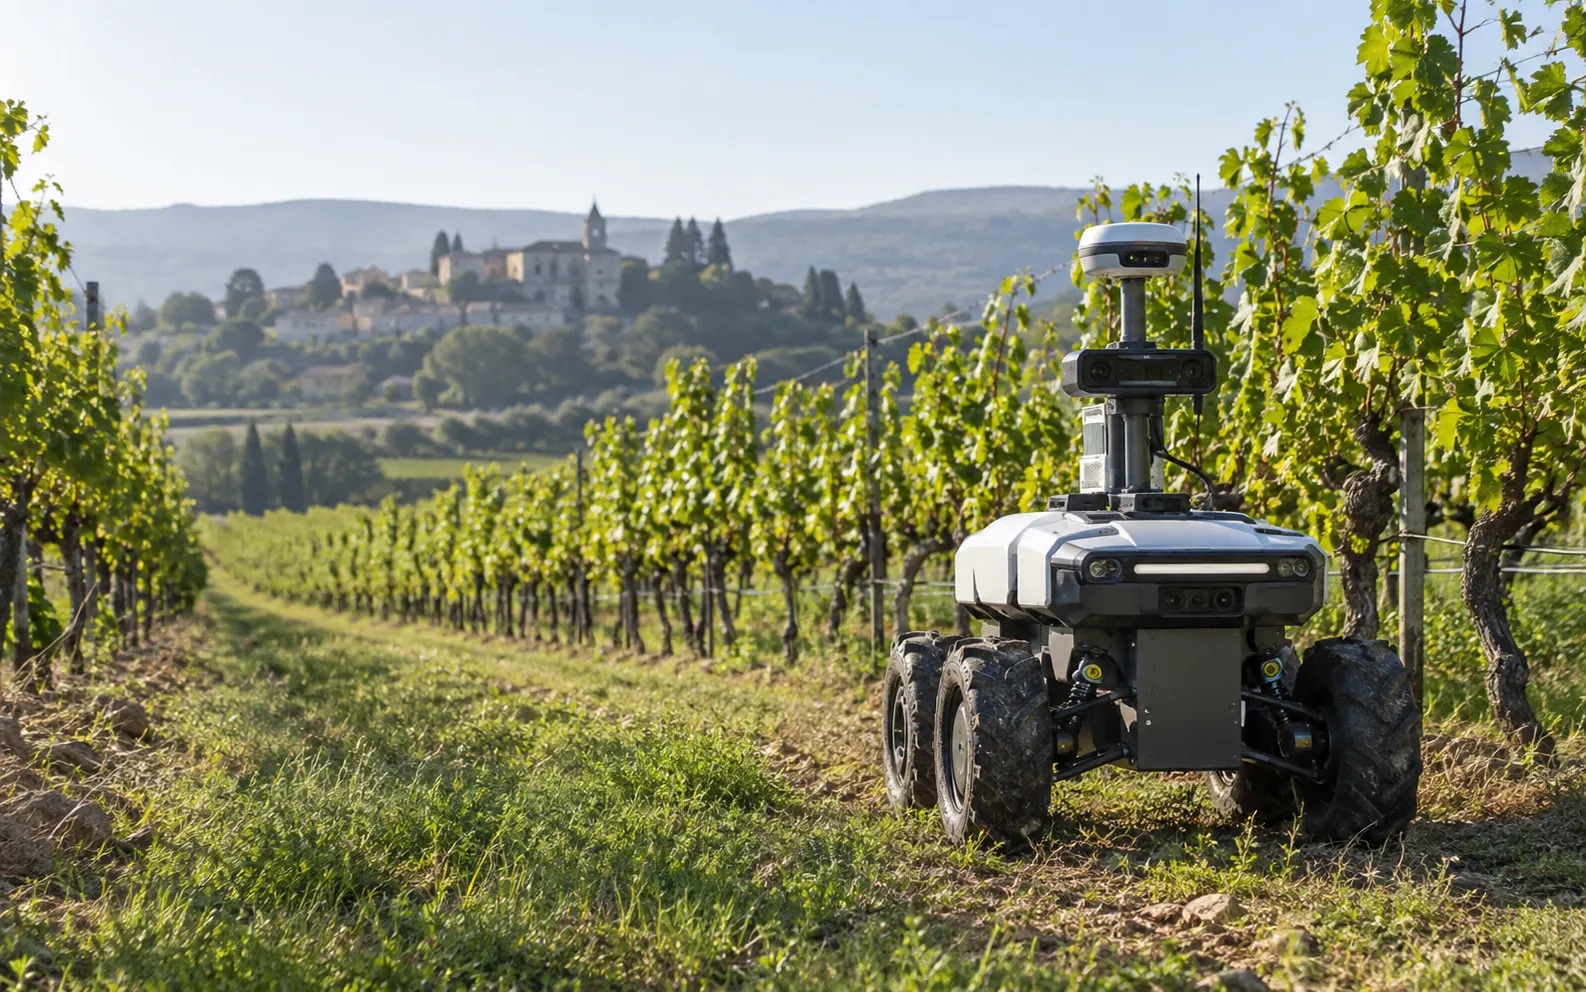
ROS 2 expertise
A modular, observable and documented ROS 2 foundation, from simulation to deployment.
/sensors/lidar ──┐
/camera/depth ───┼─▶ perception
/wheel/odom ─────┘       │
                         ▼
                    localization
                         │
                         ▼
                  nav2_controller
Our approach
Use case, environment, payload, runtime, speed, accuracy and safety.
Sensors, computing, drivetrain, mechanics and ROS 2 architecture.
Hardware/software integration, simulation and platform testing.
Measurements, logs, edge cases, documentation and technical handover.
Your project
Let’s discuss its mission, its environment and the next technical challenge.