Sensors
Integrate cameras, LiDAR, IMU, GNSS, encoders, ultrasonic and proximity sensors.
 Yokaï Robotics
Mobile robotics engineering
Discuss your project
Robotics electronics
We design and integrate the electronics that power, measure and control your mobile robot: computers, microcontrollers, sensors, motors and onboard networks.
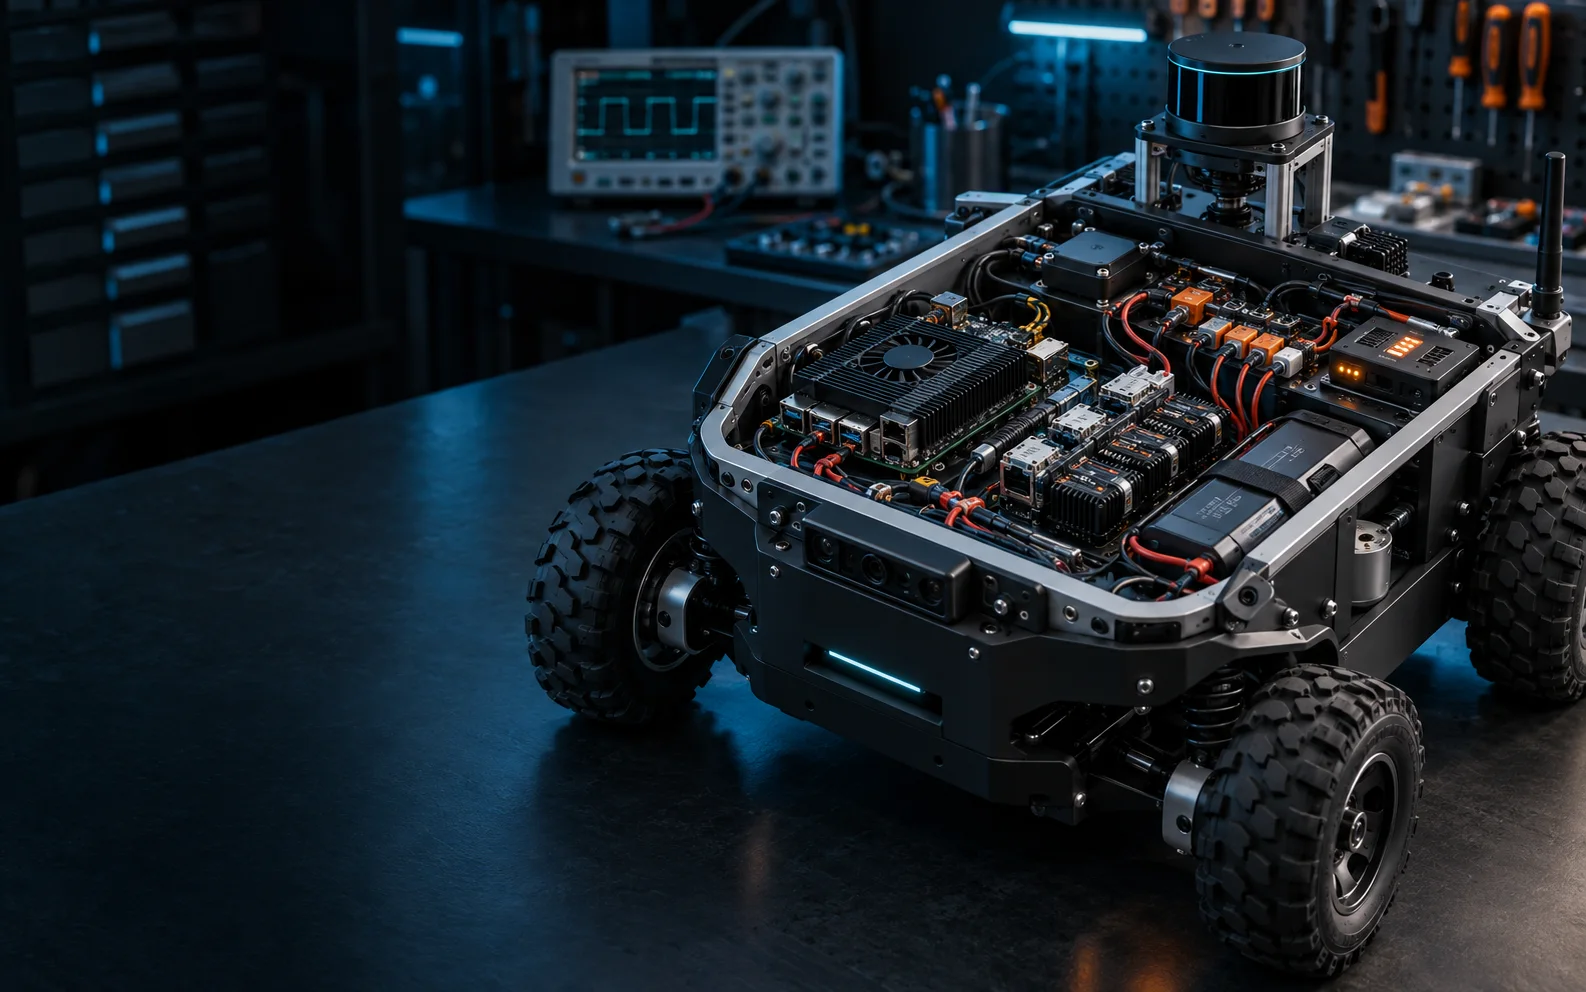
Architecture
Interfaces
Integrate cameras, LiDAR, IMU, GNSS, encoders, ultrasonic and proximity sensors.
CAN, CAN-FD, UART, SPI, I²C, USB and Ethernet with communication diagnostics.
Firmware, drivers, micro-ROS and ROS 2 interfaces to the main computer.
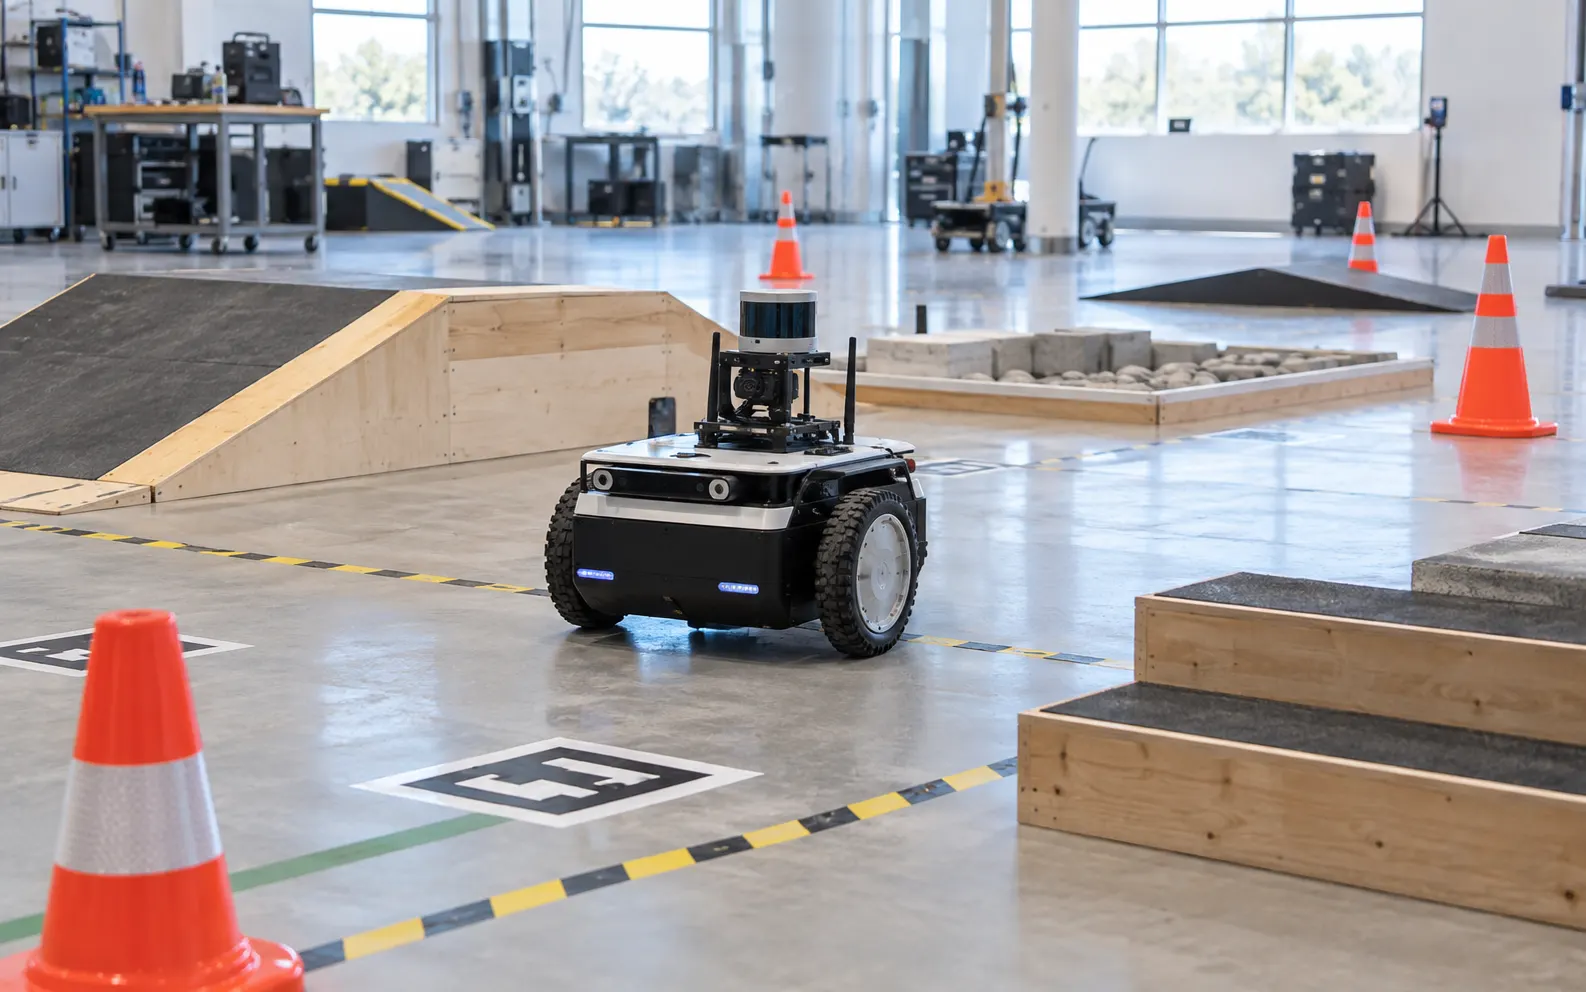
Prototyping
We first validate critical choices on a test bench, measure power consumption and signals, then document the architecture to prepare a more compact and maintainable integration.
FAQ
Yes. We check their interfaces, power supply, frequency, accuracy, drivers and mechanical compatibility before integration.
Yes, from controller selection to feedback control and odometry reporting to ROS 2.
Depending on maturity, an engagement can cover the prototype, schematic, PCB layout or preparation of a package for a manufacturing partner.
Project
Share your payload, runtime, computing and interface constraints.